Robotic arm
A low-poly shipyard robotic arm on a fixed pedestal, with a swivel turret, orange boom, hydraulic actuator, forearm, wrist and a two-finger gripper. It loops a seamless 8-second pick-and-place swing.
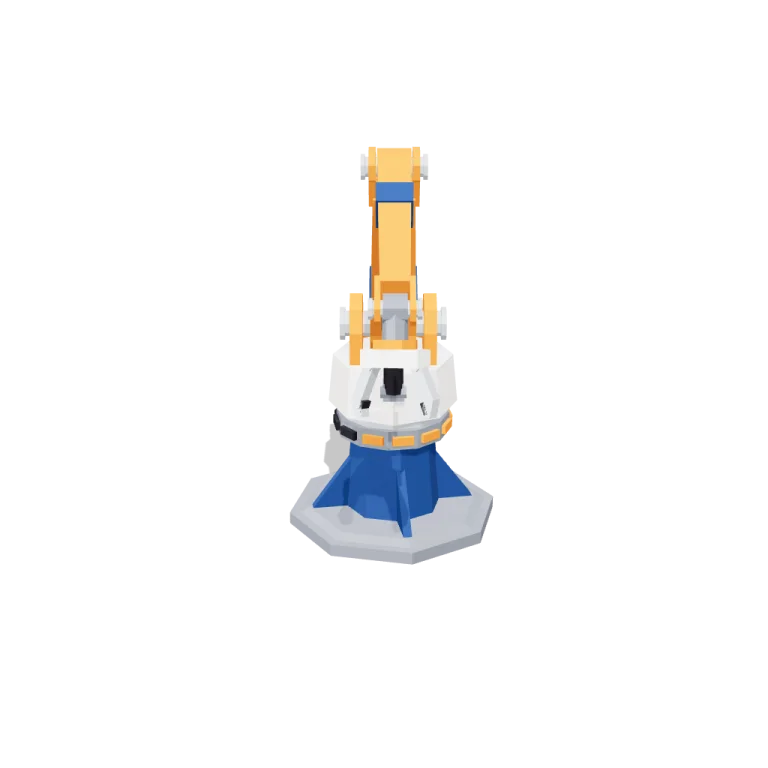
Left rail: colours and the 4 knobs the agent wrote into this model — they rebuild the geometry and go into your download. Right rail: looks for the viewer. Drag to orbit, scroll to zoom.
- Triangles
- 1,524
- Vertices
- 4,572
- Meshes · materials
- 28 · 7
- Size (W × H × D)
- 2.5 m × 3.4 m × 2.8 m
- File
- GLB · 248 KB
- Animation
- scene-motion · 8.0s
- Style
- Low-poly
- Collection
- Orbital Shipyard
Palette · named materials
- accent#ed7e1d
- base#f4f1ec
- structure#1b447e
- trim#b9bfc6
- mount#7d828c
- joint#1b1b22
- weight#af590e
Use it
import { GLTFLoader } from "three/addons/loaders/GLTFLoader.js";

const gltf = await new GLTFLoader().loadAsync(
  "https://assets.stoicsoft.com/1designtool/3d/models/orbital-shipyard-robotic-arm/7b78d5063f/model.glb"
);
scene.add(gltf.scene); // metres, +Y up, front faces +Z

const mixer = new THREE.AnimationMixer(gltf.scene);
gltf.animations.forEach((clip) => mixer.clipAction(clip).play());
// in your loop: mixer.update(delta)
How it was made
The brief given to 1DesignTool's “3D object” template:
Robotic arm for the Orbital Shipyard kit. Design it as one clear asset at believable real-world scale for that setting (state the size in metres in meta.notes), with its main parts modelled and named, readable at thumbnail size and from every orbit angle. It moves: author a seamless baked loop (2–12 s) with every pivot exactly at its hinge, axle or swivel, and keep the base still. This is one part of the Orbital Shipyard kit (Low-poly style, flat-lowpoly direction): Ships under construction in open space. Use ONLY the kit palette, by name: white #f4f1ec, orange #ed7e1d, deep space blue #1b447e, silver #b9bfc6, white dark #d7cebc, orange dark #af590e, white light #f9f8f6, orange light #eea668, soot black #1b1b22, warm white #f2ede2, mid grey #7d828c, dark wood #3d2a1c. Every material's `name` must be exactly the palette colour it uses — the GLB carries these names so the kit recolours as one; an unnamed material fails delivery. Kit knob: expose a param `shipCompletionStage` (0–1, default 0.5) for the kit's "Ship completion stage" setting wherever it makes sense on this part, and keep that id.
- Agent: Claude Code · Claude Opus 5.5 in 1DesignTool
- Generation: 4.09M tokens (95% cached) · ≈ $3.06 at API prices · 5-hour plan +8%
- Direction: Low-poly · family abstract-kinetic
- three-check PASS · glb-lint PASS
Named parts · 22
- Robotic arm
- Mount plate
- Gussets
- Pedestal
- Status collar
- Status lights
- Turret (swivel)
- Slew bearing
- Turret housing
- Shoulder cheeks
- Counterweight
- Actuator barrel
- Actuator rod
- Shoulder joint
- Boom (upper arm)
- Elbow joint
- Forearm
- Wrist pitch joint
- Wrist roll joint
- Gripper palm
- Finger (left)
- Finger (right)
Note: Real-world scale: about 3.37 m tall at rest, with a 1.72 m mount plate and about 3.0 m from the counterweight to the gripper tip. The arm reaches toward +Z. The origin is at the centre of the mount plate's underside, resting on y = 0. The base (plate, gussets, pedestal, status collar) never moves. The 8 s clip 'scene-motion' swings the turret, shoulder, elbow, wrist pitch and roll, and gripper fingers, and the hydraulic actuator tracks the shoulder. Every pivot is at its axle centre. shipCompletionStage sets how many of the 12 collar status lamps are lit (orange = lit, soot black = unlit). It is baked into the geometry when the GLB is exported, so this download has 6 of 12 lit. Like reach, it is a build-time option, and the GLB carries the default values only. sweepAngle and gripSpan only change the animation. Material names are the kit palette colour names. Meshes are flat-shaded and non-indexed on purpose, so they stay faceted in any engine. 1524 triangles. Static 'roboticarm.*' mount groups hold each moving joint; they come from the plan's part ids and do not animate. glb-lint: 0 errors. It prints UNVERIFIED because no requirements contract was supplied, and it gives 4 heuristic warnings: non-indexed flat geometry (intended), nested-part overlaps (intended), the lamps and actuator flagged as detached (they are embedded in their mounts), and a height of 3.4 m against the 1 m direction reference (real scale).
More like this
All of Orbital Shipyard →
Rotating ring
Orbital Shipyard2,484 tris

Half-built frigate
Orbital Shipyard3,860 tris

Tug ship
Orbital Shipyard3,184 tris

Cable reels
Orbital Shipyard4,052 tris

Signal lights
Orbital Shipyard1,124 tris

Thruster units
Orbital Shipyard2,456 tris

Welding sparks
Orbital Shipyard2,772 tris

Cargo pods
Orbital Shipyard2,100 tris
Free under the 1DesignTool 3D library license. Model #10 of 589.